Helloo, I’m completing Quiz 3.10 – Topics Quiz in ROS2 Basics in 5 Days.
Gradebot repeatedly reports that my node is not subscribed to /odom, but my ROS2 diagnostics show that the subscription exists correctly.
When I run ros2 topic info /odom -v while the sim is running, it shows
My package also builds and launches successfully, and the rover works correctly when tested manually. It receives the Go-Pickup command, moves to the required coordinates while avoiding obstacles, and stops once the goal is reached.
I have reset the terminals and simulation and allowed Gradebot to build and launch the package itself, but I still receive the same /odom grading error.
Could you please check whether this is an issue with the Gradebot/autocorrection?
Thank you.
Hi @ngg1523
I have checked personally your code and everything is correct. The robot does what is requested by the quiz.
Then I have checked your previous feedback from the Gradebot and it said that you had a problem with the /odom topic. That is the old feedback. In order to get a new feedback, you need to launch again the Gradebot, so it can check for your changes.
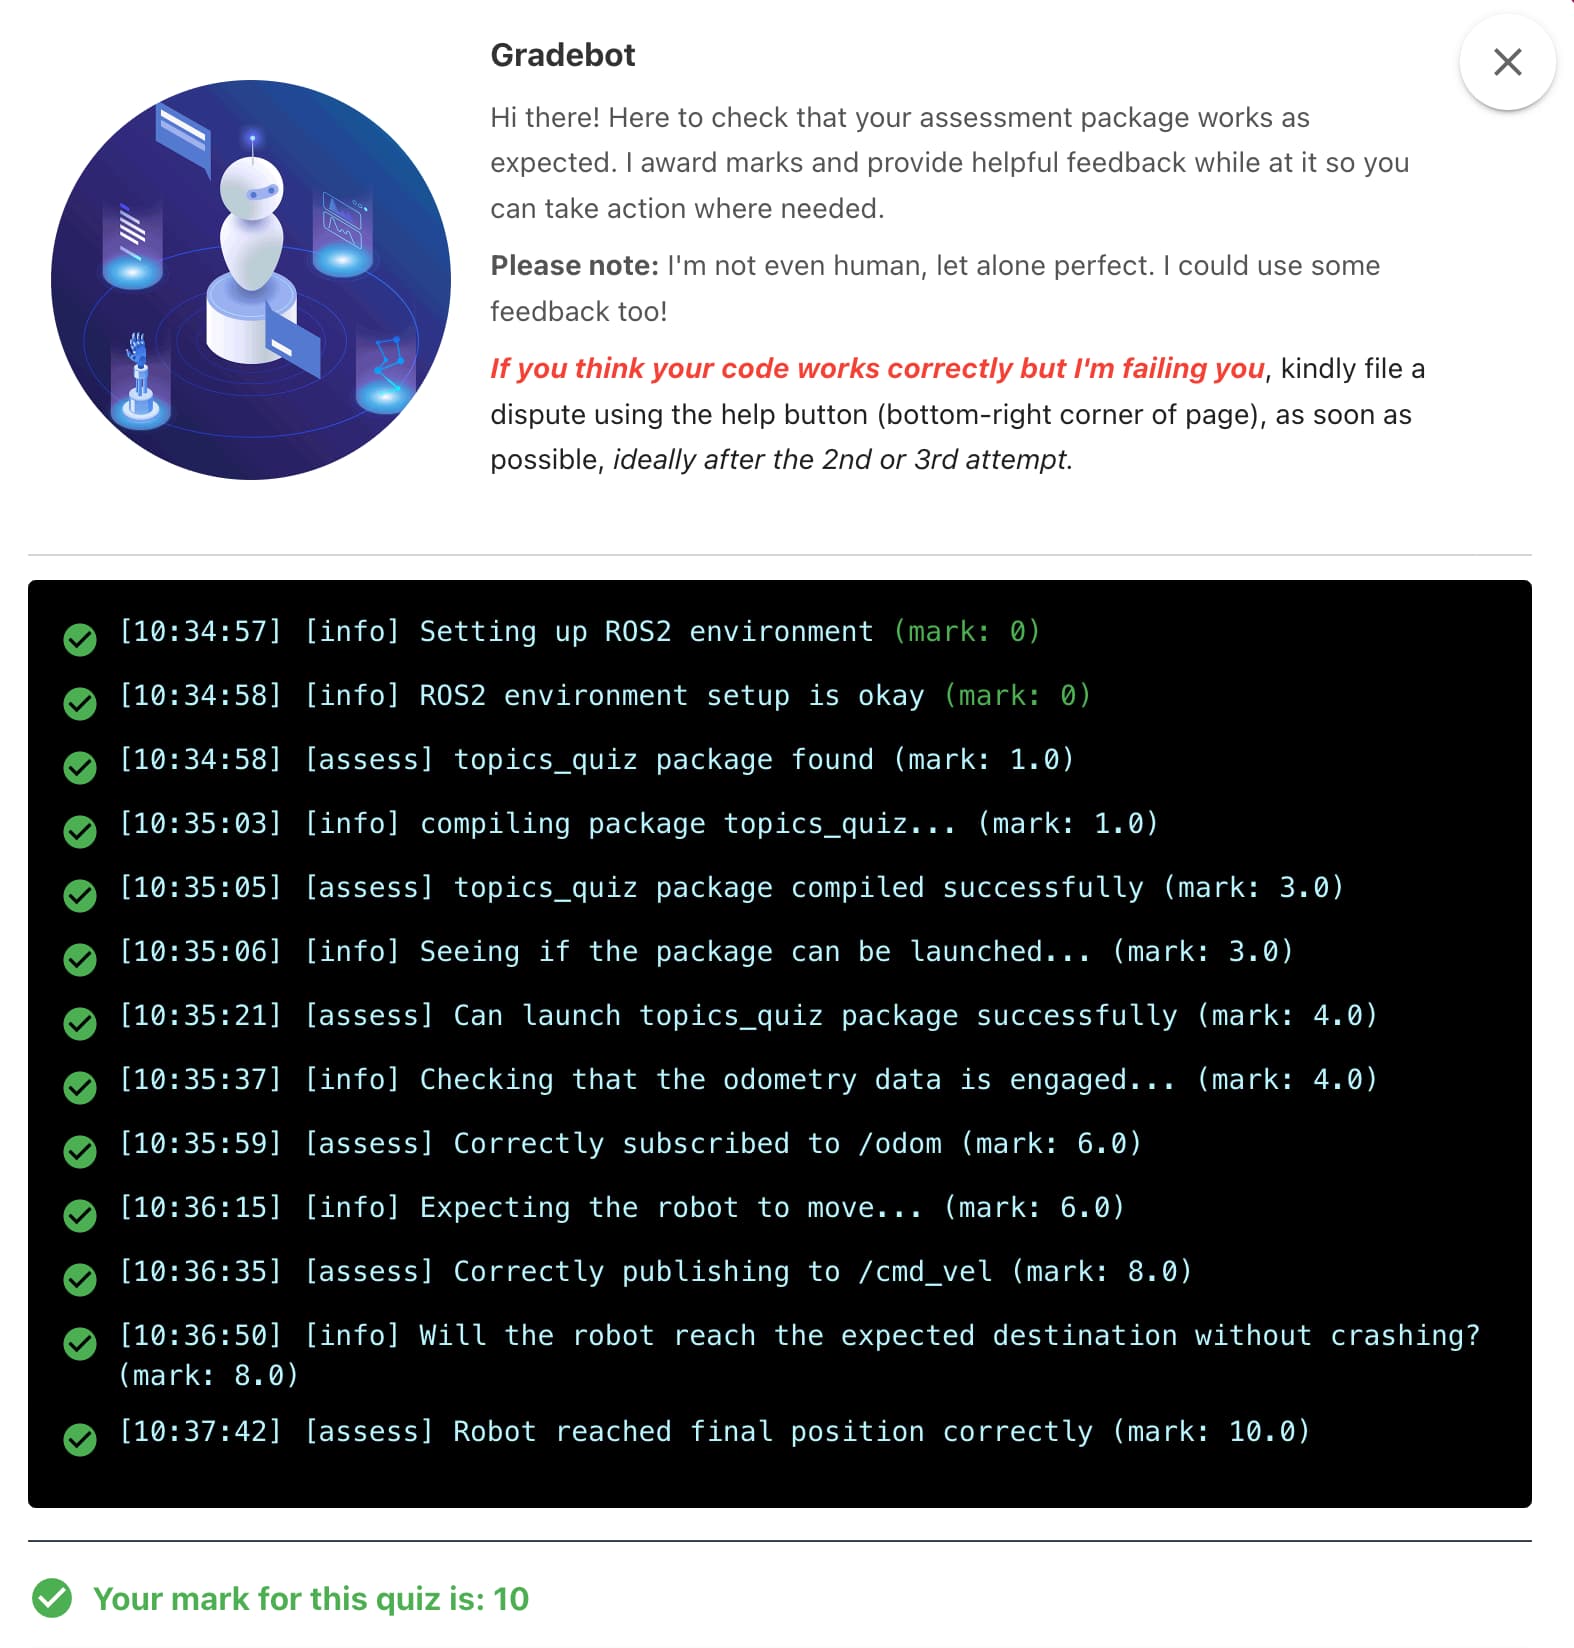
So I launched the Gradebot with your code and of course it said everything was correct and you got a full pass (10 out of 10).
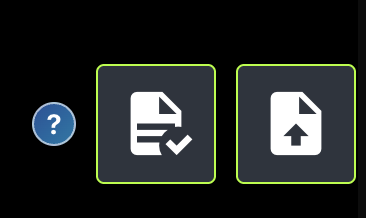
I think you confused the two buttons:
- If you click on the button of the left, you will get the latest Gradebot evaluation
- If you click on the button of the right, you will start a new Gradebot review. This is the button I pressed and said your code is correct
So every time you do changes and want to see if those changes solved the problem, you need to grade again.