I subscribed to ROS2 Manipulation Basics course as I thought it would teach about how I can connect to a real universal Robot. I am a beginner in this field and learning this course so that I can connect to a real robot and not in a simulated environment.
Is there any course or any way I can actually configure and connect to a real universal robot?
@sumitkumar2801
If your robot supports ROS, we have the resources to help you do just that! The following are the steps required for a beginner.
- Learn how to control both simulated and real robots with ROS by taking the ROS2 Basics course.
- Python version of the course
- C++ version of the course
- The course teaches about controlling simulated robots first, then how to make the code work on a real robot.
- You learn to control real robot by connecting remotely to one of our real robots.
- You need some knowledge of Python or C++ and Linux. If you are not familiar with any of these, we also have courses for that:
- Add your real robot on the real robots page, and
- Control it using a ROS project you create on the platform, using the knowledge acquired for the ROS2 Basics course.
- Learn the ROS2 Manipulation course, then
- Test your knowledge in a simulation first, then
- Apply the knowledge to the real robot.
Hi @bayodesegun,
Thank you so much for your reply. I am actually familiar with Linux and ROS2. I have an UR5e real robot which I can control through ROS2 humble. But with UR5e I have attached a wrist camera and 2f-85 gripper from Robotiq. And now I am trying to control UR5e + wrist camera + 2f-85 gripper with ros2. I cannot find URDF file for wrist camera, but I was able to add gripper to it and simulate it in Gazebo. But I am not sure how to connect transmission for controlling both (robot+gripper) with ROS2 and how to configure the URDF and SRDF for real robot with wrist camera and gripper.
Moreover, I am not sure how I can attach/register my robot to construct platform with a bash file. Where and how to run the file?
I was hoping to learn how to connect and configure a real robot in construct platform but its only simulation… 
No, it’s not only simulation, as I explained earlier. We teach working with real robots in the ros2 basics course.
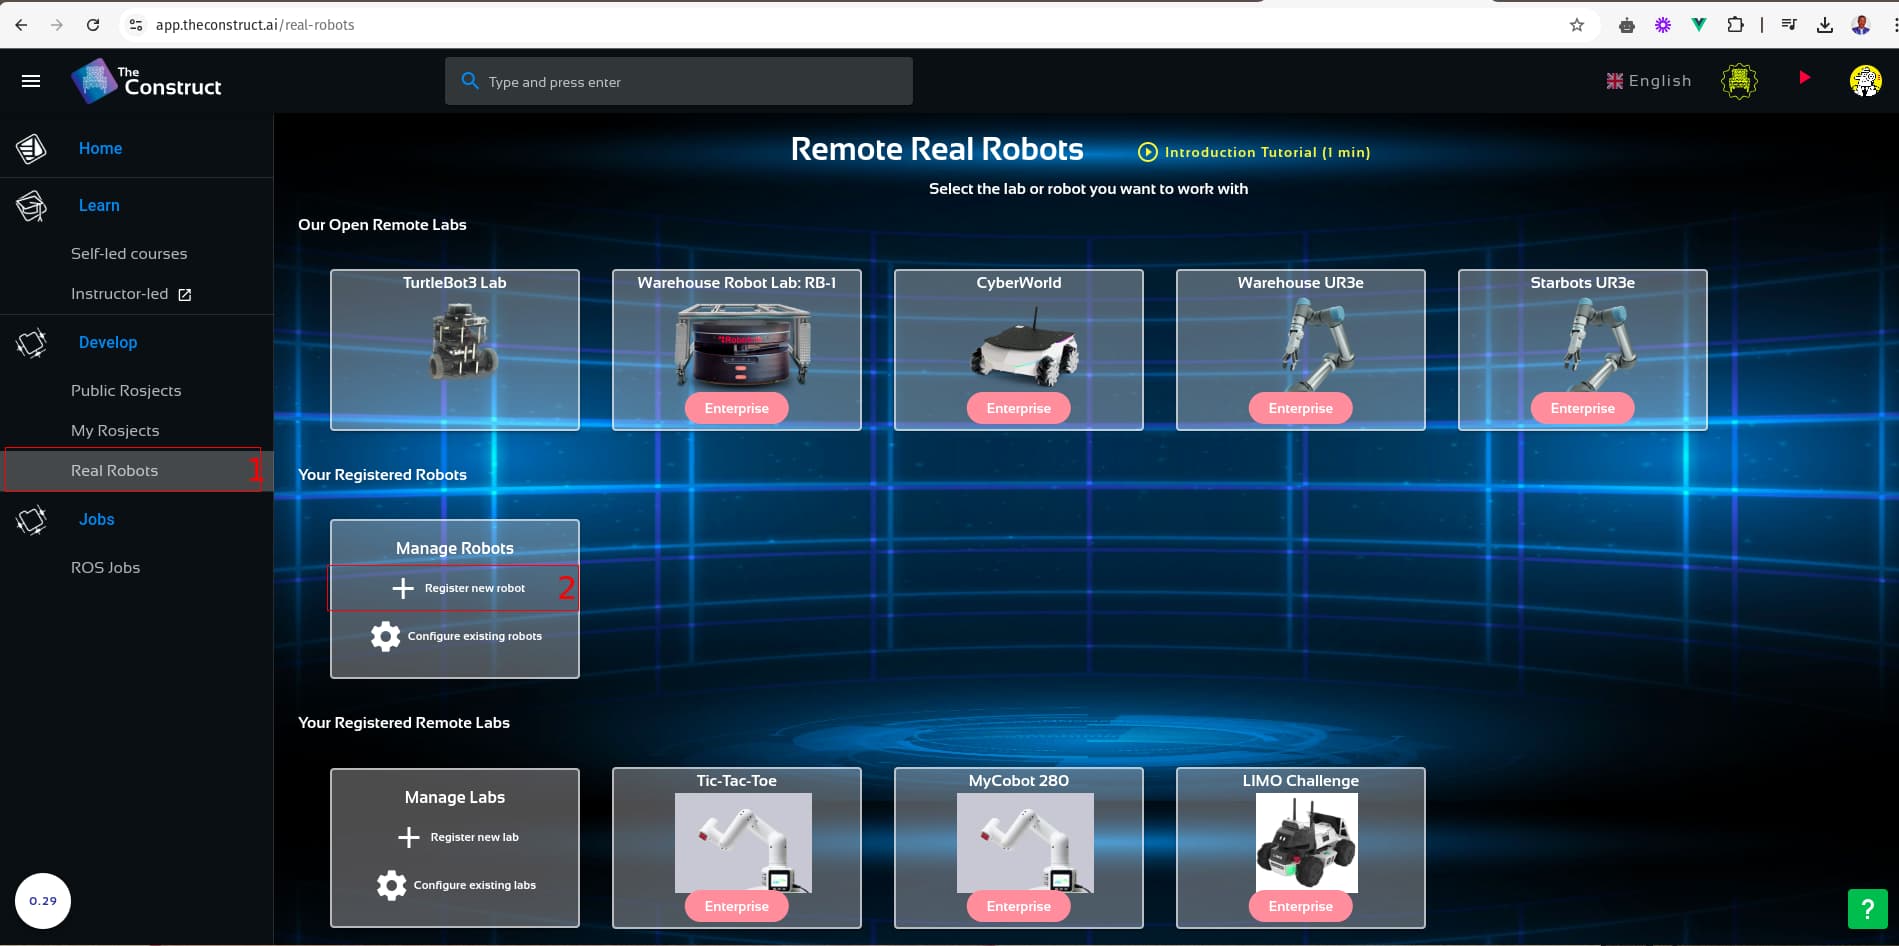
Configuring a robot is as simple as ABC:
- Visit the Real Robots page.
- Click Register new robot
- Select Manual Registration
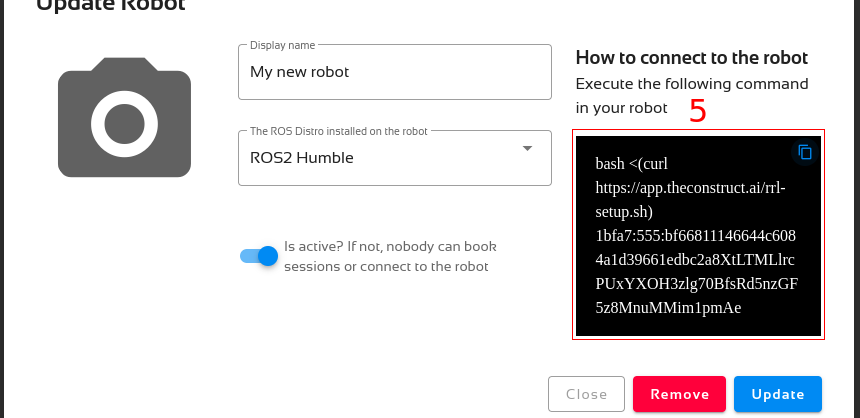
- Add a name for your robot, select the ROS distro running on it, activate the active switch and click Register.
- Copy the bash command shown and run it on the terminal of your robot (your robot manual should tell you how to access this).
- This would install some packages and the module for communicating with the platform. You would see a success message when it finishes
Please let us know if you run into any issue.