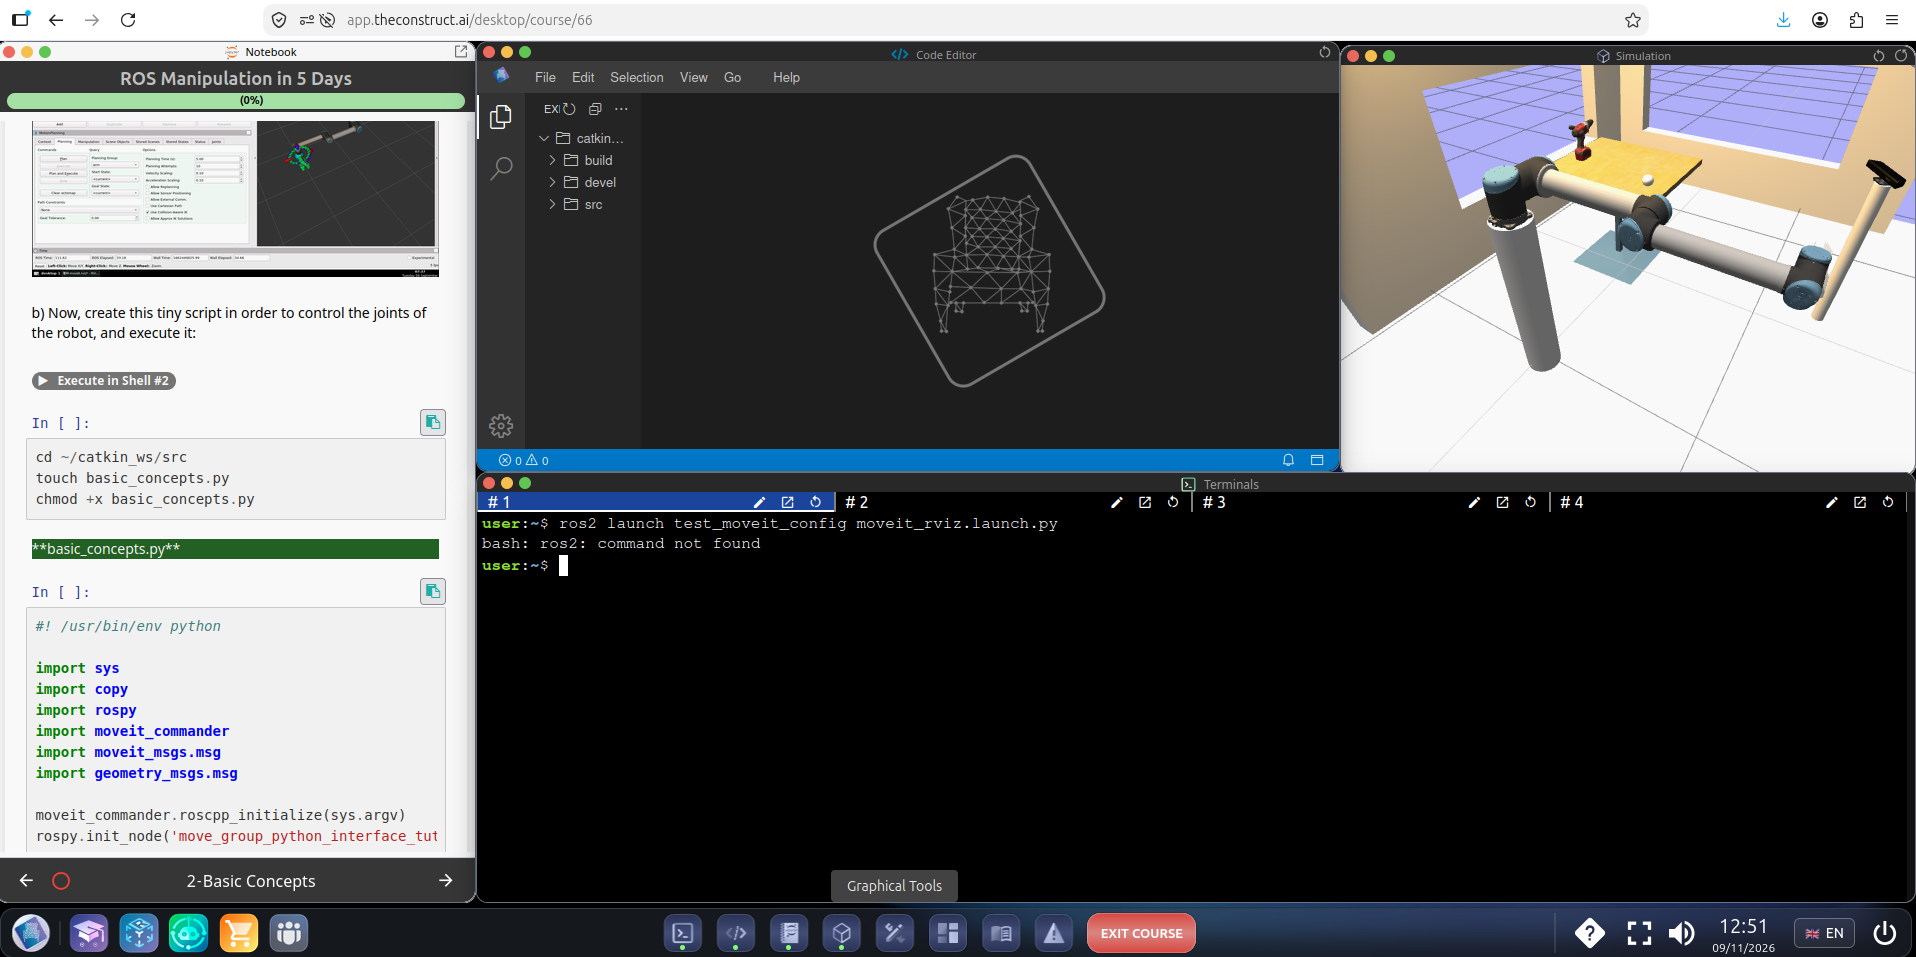
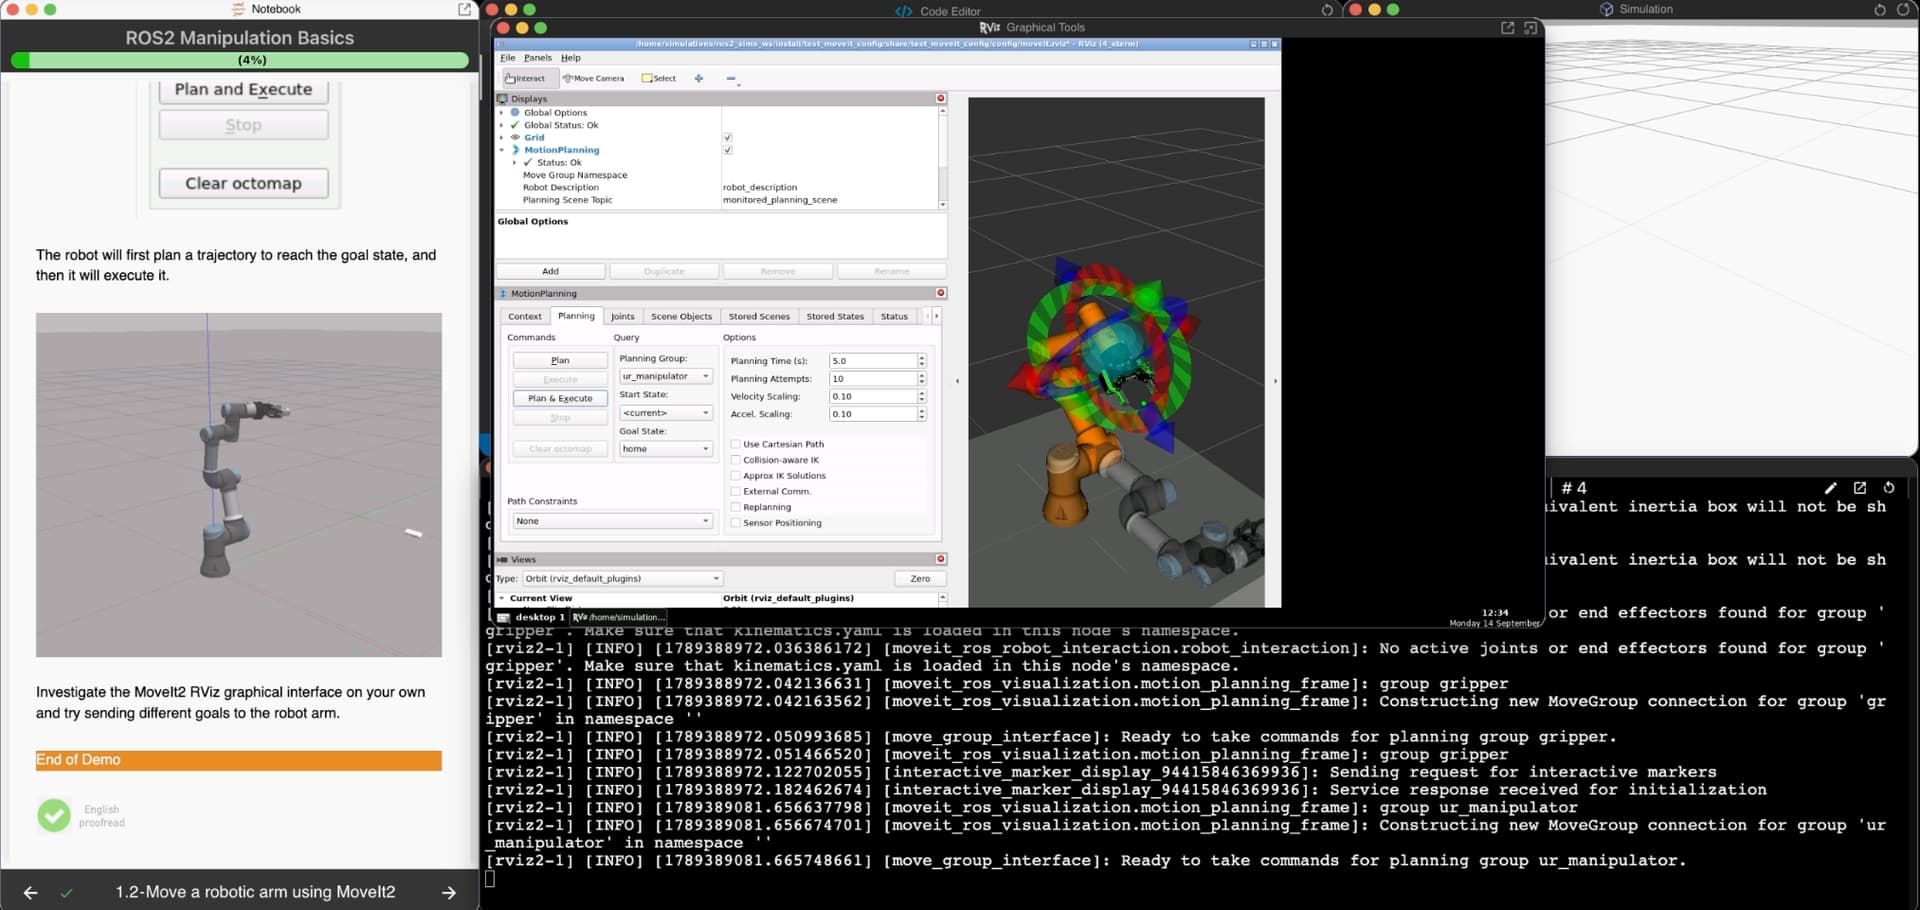
no graphical interface is launched. the shell shows no obvious error either:
ser:~$ ros2 launch test_moveit_config moveit_rviz.launch.py
[INFO] [launch]: All log files can be found below /home/user/.ros/log/2026-09-11-10-35-20-074106-4_xterm-6600
[INFO] [launch]: Default logging verbosity is set to INFO
[INFO] [rviz2-1]: process started with pid [6601]
[rviz2-1] QStandardPaths: XDG_RUNTIME_DIR not set, defaulting to '/tmp/runtime-user'
[rviz2-1] [INFO] [1789122920.620660949] [rviz2]: Stereo is NOT SUPPORTED
[rviz2-1] [INFO] [1789122920.620739928] [rviz2]: OpenGl version: 4.5 (GLSL 4.5)
[rviz2-1] [INFO] [1789122920.639729277] [rviz2]: Stereo is NOT SUPPORTED
[rviz2-1] Warning: class_loader.impl: SEVERE WARNING!!! A namespace collision has occurred with plugin factory for class rviz_default_plugins::displays::InteractiveMarkerDisplay. New factory will OVERWRITE existing one. This situation occurs when libraries containing plugins are directly linked against an executable (the one running right now generating this message). Please separate plugins outinto their own library or just don't link against the library and use either class_loader::ClassLoader/MultiLibraryClassLoader to open.
[rviz2-1]          at line 253 in /opt/ros/humble/include/class_loader/class_loader/class_loader_core.hpp
[rviz2-1] [ERROR] [1789122923.987908254] [moveit_ros_visualization.motion_planning_frame]: Action server: /recognize_objects not available
[rviz2-1] [INFO] [1789122924.001030303] [moveit_ros_visualization.motion_planning_frame]: MoveGroup namespace changed: / -> . Reloading params.
[rviz2-1] [INFO] [1789122924.158227466] [moveit_rdf_loader.rdf_loader]: Loaded robot model in 0.0802552 seconds
[rviz2-1] [INFO] [1789122924.158271932] [moveit_robot_model.robot_model]: Loading robot model 'name'...
[rviz2-1] [INFO] [1789122924.265755664] [moveit_ros.planning_scene_monitor.planning_scene_monitor]: Starting planning scene monitor
[rviz2-1] [INFO] [1789122924.266439748] [moveit_ros.planning_scene_monitor.planning_scene_monitor]: Listening to '/monitored_planning_scene'
[rviz2-1] [ERROR] [1789122924.392810500] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789122924.393209136] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789122924.601413802] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789122924.601769684] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [INFO] [1789122924.609675670] [interactive_marker_display_94570803928208]: Connected on namespace: /rviz_moveit_motion_planning_display/robot_interaction_interactive_marker_topic
[rviz2-1] [ERROR] [1789122924.610678048] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789122924.611131405] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789122924.613856654] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789122924.614313173] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [INFO] [1789122924.616700500] [moveit_ros_robot_interaction.robot_interaction]: No active joints or end effectors found for group 'gripper'. Make sure that kinematics.yaml is loaded in this node's namespace.
[rviz2-1] [INFO] [1789122924.617366018] [moveit_ros_robot_interaction.robot_interaction]: No active joints or end effectors found for group 'gripper'. Make sure that kinematics.yaml is loaded in this node's namespace.
[rviz2-1] [INFO] [1789122924.624128987] [moveit_ros_visualization.motion_planning_frame]: group gripper
[rviz2-1] [INFO] [1789122924.624148212] [moveit_ros_visualization.motion_planning_frame]: Constructing new MoveGroup connection for group 'gripper' in namespace ''
[rviz2-1] [INFO] [1789122924.634190788] [move_group_interface]: Ready to take commands for planning group gripper.
[rviz2-1] [INFO] [1789122924.634562341] [moveit_ros_visualization.motion_planning_frame]: group gripper
[rviz2-1] [INFO] [1789122924.704312950] [interactive_marker_display_94570803928208]: Sending request for interactive markers
[rviz2-1] [INFO] [1789122924.761895305] [interactive_marker_display_94570803928208]: Service response received for initialization
could it be related to these Errors on startup of rviz?
user:~$ ros2 launch test_moveit_config moveit_rviz.launch.py
[INFO] [launch]: All log files can be found below /home/user/.ros/log/2026-09-14-12-42-38-116277-4_xterm-8156
[INFO] [launch]: Default logging verbosity is set to INFO
[INFO] [rviz2-1]: process started with pid [8158]
[rviz2-1] QStandardPaths: XDG_RUNTIME_DIR not set, defaulting to '/tmp/runtime-user'
[rviz2-1] [INFO] [1789389758.656435262] [rviz2]: Stereo is NOT SUPPORTED[rviz2-1] [INFO] [1789389758.656524103] [rviz2]: OpenGl version: 4.5 (GLSL 4.5)[rviz2-1] [INFO] [1789389758.673985724] [rviz2]: Stereo is NOT SUPPORTED
[rviz2-1] Warning: class_loader.impl: SEVERE WARNING!!! A namespace collision has occurred with plugin factory for class rviz_default_plugins
::displays::InteractiveMarkerDisplay. New factory will OVERWRITE existing one. This situation occurs when libraries containing plugins are di
rectly linked against an executable (the one running right now generating this message). Please separate plugins out into their own library or just don't link against the library and use either class_loader::ClassLoader/MultiLibraryClassLoader to open.[rviz2-1]          at line 253 in /opt/ros/humble/include/class_loader/class_loader/class_loader_core.hpp
[rviz2-1] [ERROR] [1789389761.782145831] [moveit_ros_visualization.motion_planning_frame]: Action server: /recognize_objects not available
[rviz2-1] [INFO] [1789389761.794961337] [moveit_ros_visualization.motion_planning_frame]: MoveGroup namespace changed: / -> . Reloading param
s.
[rviz2-1] [INFO] [1789389761.918710556] [moveit_rdf_loader.rdf_loader]: Loaded robot model in 0.0796896 seconds
[rviz2-1] [INFO] [1789389761.918761023] [moveit_robot_model.robot_model]: Loading robot model 'name'...
[rviz2-1] [INFO] [1789389762.025286987] [moveit_ros.planning_scene_monitor.planning_scene_monitor]: Starting planning scene monitor
[rviz2-1] [INFO] [1789389762.026083476] [moveit_ros.planning_scene_monitor.planning_scene_monitor]: Listening to '/monitored_planning_scene'
[rviz2-1] [ERROR] [1789389762.145456660] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789389762.145857080] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789389762.349409744] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789389762.349823620] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [INFO] [1789389762.358069924] [interactive_marker_display_94733985661952]: Connected on namespace: /rviz_moveit_motion_planning_display/robot_interaction_interactive_marker_topic
[rviz2-1] [ERROR] [1789389762.359232389] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789389762.359757217] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789389762.362846836] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [ERROR] [1789389762.363366367] [rviz2]: The link is static or has unrealistic inertia, so the equivalent inertia box will not be shown.
[rviz2-1]
[rviz2-1] [INFO] [1789389762.366146698] [moveit_ros_robot_interaction.robot_interaction]: No active joints or end effectors found for group 'gripper'. Make sure that kinematics.yaml is loaded in this node's namespace.
[rviz2-1] [INFO] [1789389762.366917629] [moveit_ros_robot_interaction.robot_interaction]: No active joints or end effectors found for group 'gripper'. Make sure that kinematics.yaml is loaded in this node's namespace.
[rviz2-1] [INFO] [1789389762.372368444] [moveit_ros_visualization.motion_planning_frame]: group gripper
[rviz2-1] [INFO] [1789389762.372390223] [moveit_ros_visualization.motion_planning_frame]: Constructing new MoveGroup connection for group 'gripper' in namespace ''
[rviz2-1] [INFO] [1789389762.382108487] [move_group_interface]: Ready to take commands for planning group gripper.
[rviz2-1] [INFO] [1789389762.450811628] [interactive_marker_display_94733985661952]: Sending request for interactive markers
[rviz2-1] [INFO] [1789389762.502162613] [interactive_marker_display_94733985661952]: Service response received for initialization
O
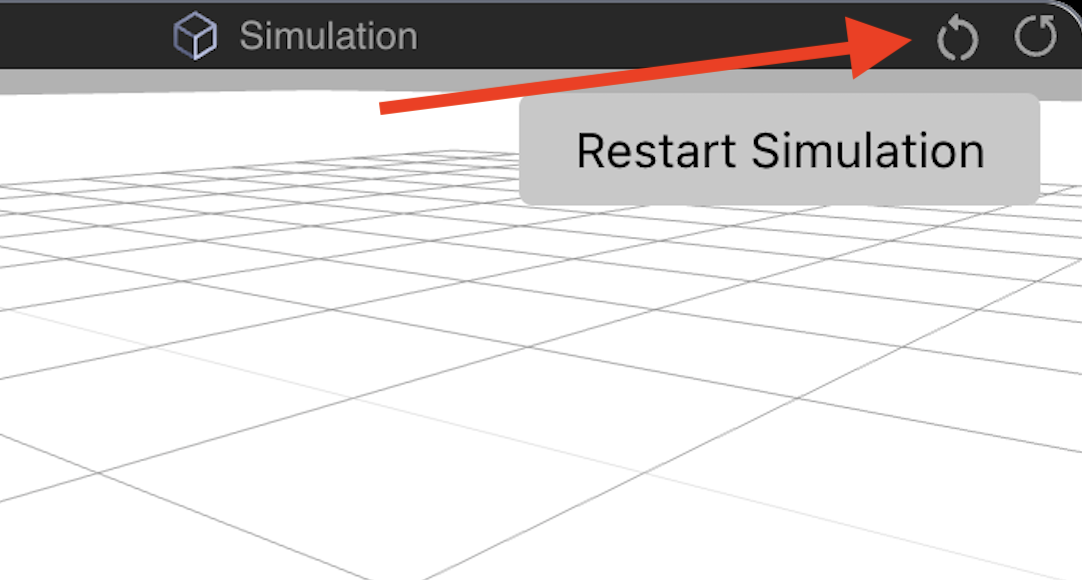
The issue here seems to be that the simulation broke or did not start correctly, hence Moveit was not able to control the arm properly and the robot arm was lying on the ground. If this happens again, Restart the simulation using the button available in the Simulation window:
After restarting the simulation, the arm should appear straight up and Moveit should work correctly.
Also, in case you run into other issues in the future, make sure to check out the Moveit’s console output, not RViz’s output. If there’s any problem with Moveit, the error messages will show up there.
Let us know if you are able to fix your issue with these steps.
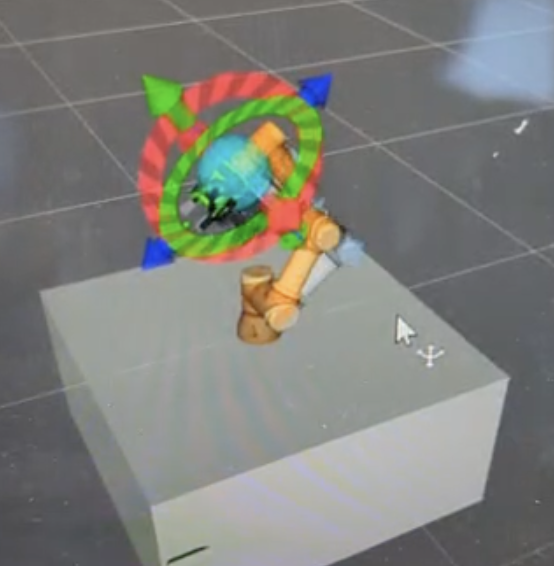
Hi Alberto, thanks for the hint. when i restarted the tutorial it worked and execution succeeded (i can see it on the simulation). The only odd thing is that on rviz the goal model (in orange) of the robot is correct, but the robot’s model hasnt completed the execution and keeps moving towards the goal, then resets to its own position and tries to move again. I cant upload videos but you can see a screenshot here:
That is normal. It’s just an animation that is played by RViz in a loop to help visualize the path the robot has followed (or is going to follow). Don’t worry about it.