Hello everyone,
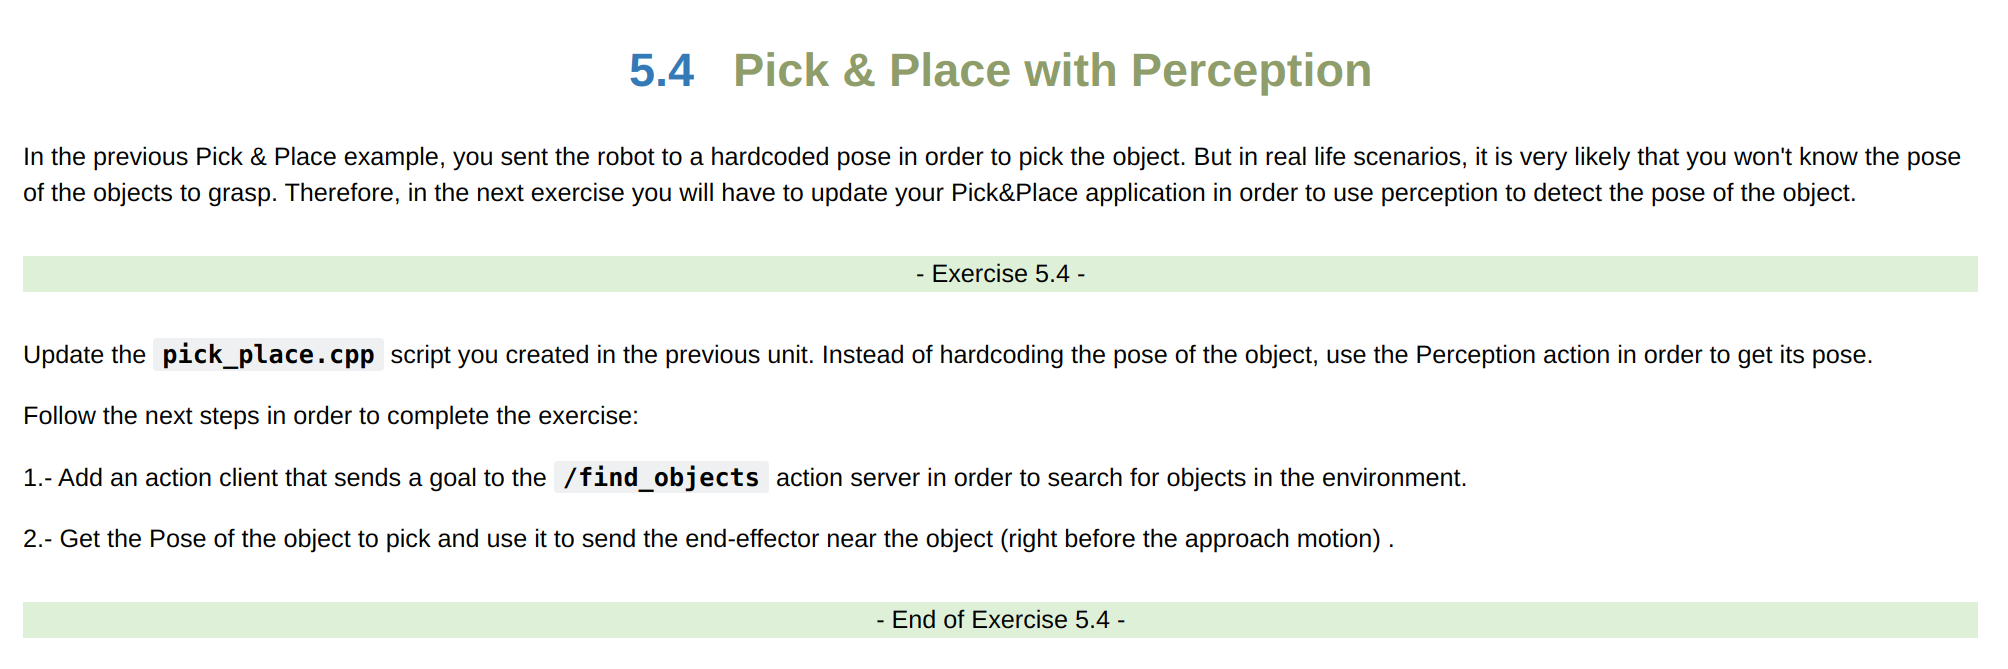
In the chapter 5 for the last exercise (exercise 5.4), I didn’t succeed to do it. Does somebody have done it and can share the answer please ?
Thank you!
Hi @Brubotics ,
Welcome to the Community!
It is quite easy to do this task. I will give you the steps to the solution, try to code it yourself.
- Launch the perception action server.
- Make an action request to get all the detected objects.
- From the action result, get the dimensions and poses of the objects.
- Now filter the object based on its detected dimensions.
- Once you have selected the object to pick, use the manipulator to go to that pose.
- Open the gripper, do the approach-retreat motion. You might have to add some offsets pysically.
- Close the gripper to grasp the object.
- Move the arm to the place position.
- Open the gripper to release the object.
- Get back to a home position.
You need to make an action call to /find_objects action server to get the list of detected objects and their dimensions and poses.
I hope this helps!
Regards,
Girish