Hello,
I have create code for three utrasone sensors on my robot. When I do a rostopic echo /RightSonarDistance the correct values are displayed on the terminal. So that seems to work.
No I have created axacro robot model which loads correctly into RViz but it should show the sensor output. Unfortunately I can get it work correctly.
This is how my xacro file looks like, at the bottom is the sensor definition:
<?xml version="1.0"?>
<robot xmlns:xacro="http://ros.org/wiki/xacro" name="r2g2">

  <!-- Define the material for visualization -->
  <material name="gray">
    <color rgba="0.5 0.5 0.5 1"/>
  </material>

  <!-- Define the wheel radius and separation distance -->
  <xacro:property name="base_width" value="0.17"/>
  <xacro:property name="base_len" value="0.27"/>
  <xacro:property name="wheel_radius" value="0.035"/>
  <xacro:property name="base_wheel_gap" value="0.007"/>
  <xacro:property name="wheel_separation" value="0.17"/>
  <xacro:property name="wheel_joint_offset" value="0.045"/>


  <!--Base Footprint-->
  <link name="base_footprint">
    <visual>
        <origin xyz="0 0 0" rpy="0 0 0" />
        <geometry>
            <box size="0.001 0.001 0.001" />
        </geometry>
    </visual>
  </link>

  <!-- Base Link -->
  <link name="base_link">
    <visual>
      <origin rpy="0 0 0" xyz="0 0 0"/>
      <geometry>
        <box size="${base_len} ${base_width} 0.01"/>
      </geometry>
      <material name="gray"/>
    </visual>
  </link>

    <!--base_link to base_footprint Joint-->
  <joint name="base_link_joint" type="fixed">
    <origin xyz="0 0 0" rpy="0 0 0" />
    <parent link="base_footprint"/>
    <child link="base_link" />
  </joint>

    <!-- Left Wheel and Link-->
  <link name="left_wheel_link">
    <visual>
      <origin xyz="0 0 0" rpy="${pi/2} 0 0" />
        <geometry>
          <cylinder radius="${wheel_radius}" length="0.009"/>
        </geometry>
        <material name="gray"/>
    </visual>
    <collision>
      <origin xyz="0 0 0" rpy="${pi/2} 0 0"/>
        <geometry>
          <cylinder radius="${wheel_radius}" length="0.009"/>
        </geometry>
    </collision>

  </link>

  <joint name="left_wheel_joint" type="continuous">
      <axis xyz="0 1 0" rpy="0 0 0" />
      <parent link="base_link"/>
      <child link="left_wheel_link"/>
      <origin xyz="${wheel_joint_offset} ${((base_width/2)+base_wheel_gap)*1} -0.005" rpy="0 0 0"/>
  </joint>

    <!-- Right Wheel and Link-->
  <link name="right_wheel_link">
    <visual>
      <origin xyz="0 0 0" rpy="${pi/2} 0 0" />
        <geometry>
          <cylinder radius="${wheel_radius}" length="0.009"/>
        </geometry>
        <material name="gray"/>
    </visual>
    <collision>
      <origin xyz="0 0 0" rpy="${pi/2} 0 0"/>
        <geometry>
          <cylinder radius="${wheel_radius}" length="0.009"/>
        </geometry>
    </collision>
  </link>

  <joint name="right_wheel_joint" type="continuous">
      <axis xyz="0 1 0" rpy="0 0 0" />
      <parent link="base_link"/>
      <child link="right_wheel_link"/>
      <origin xyz="${wheel_joint_offset} ${((base_width/2)+base_wheel_gap)*-1} -0.005" rpy="0 0 0"/>
  </joint>

    <!-- Right Ultrasone sensor-->
  <joint name="right_ultrasone_joint" type="fixed">
      <axis xyz="0 1 0" rpy="0 0 0" />
      <parent link="base_link"/>
      <child link="right_ultrasone_link"/>
      <origin xyz="${(base_len/2)} ${(base_width/2)*-1} -0.01" rpy="0 0 0.523598"/>
  </joint>

  <link name="right_ultrasone_link">
    <visual>
      <origin xyz="0 0 0" rpy="${pi/2} 0 0" />
        <geometry>
          <cylinder radius="0.005" length="0.015"/>
        </geometry>
        <material name="gray"/>
    </visual>
    <collision>
      <origin xyz="0 0 0" rpy="${pi/2} 0 0"/>
        <geometry>
          <cylinder radius="0.005" length="0.015"/>
        </geometry>
    </collision>
  </link>

</robot>
Here a screenshot of the output of RViz
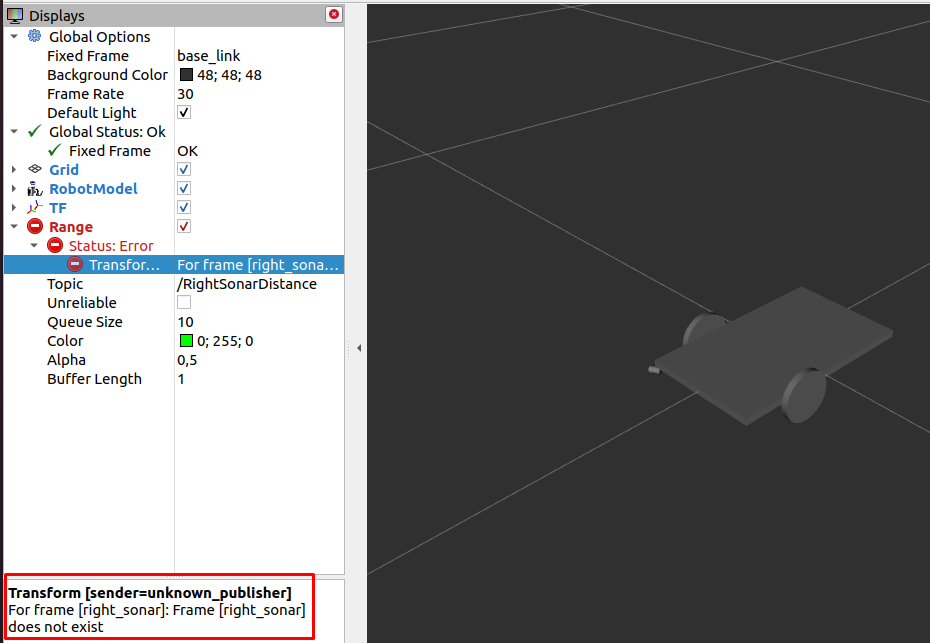
RViz tells me that
right_sonar frame does not exist. But I dont know how to fix this could anybody point me out what I am doing wrong?